Retail × Embodied Intelligence

Retail Reality Is the Training Ground for Embodied Intelligence

REAL STORES · REAL TASKS · REAL INTERACTIONS

20,000+Data Hours
100+Capture Devices
20,000+SKUs Covered
COLLECTION HOURS AS OF
02 / Field Evidence

Captured in Real Work,
Not Staged for a Demo

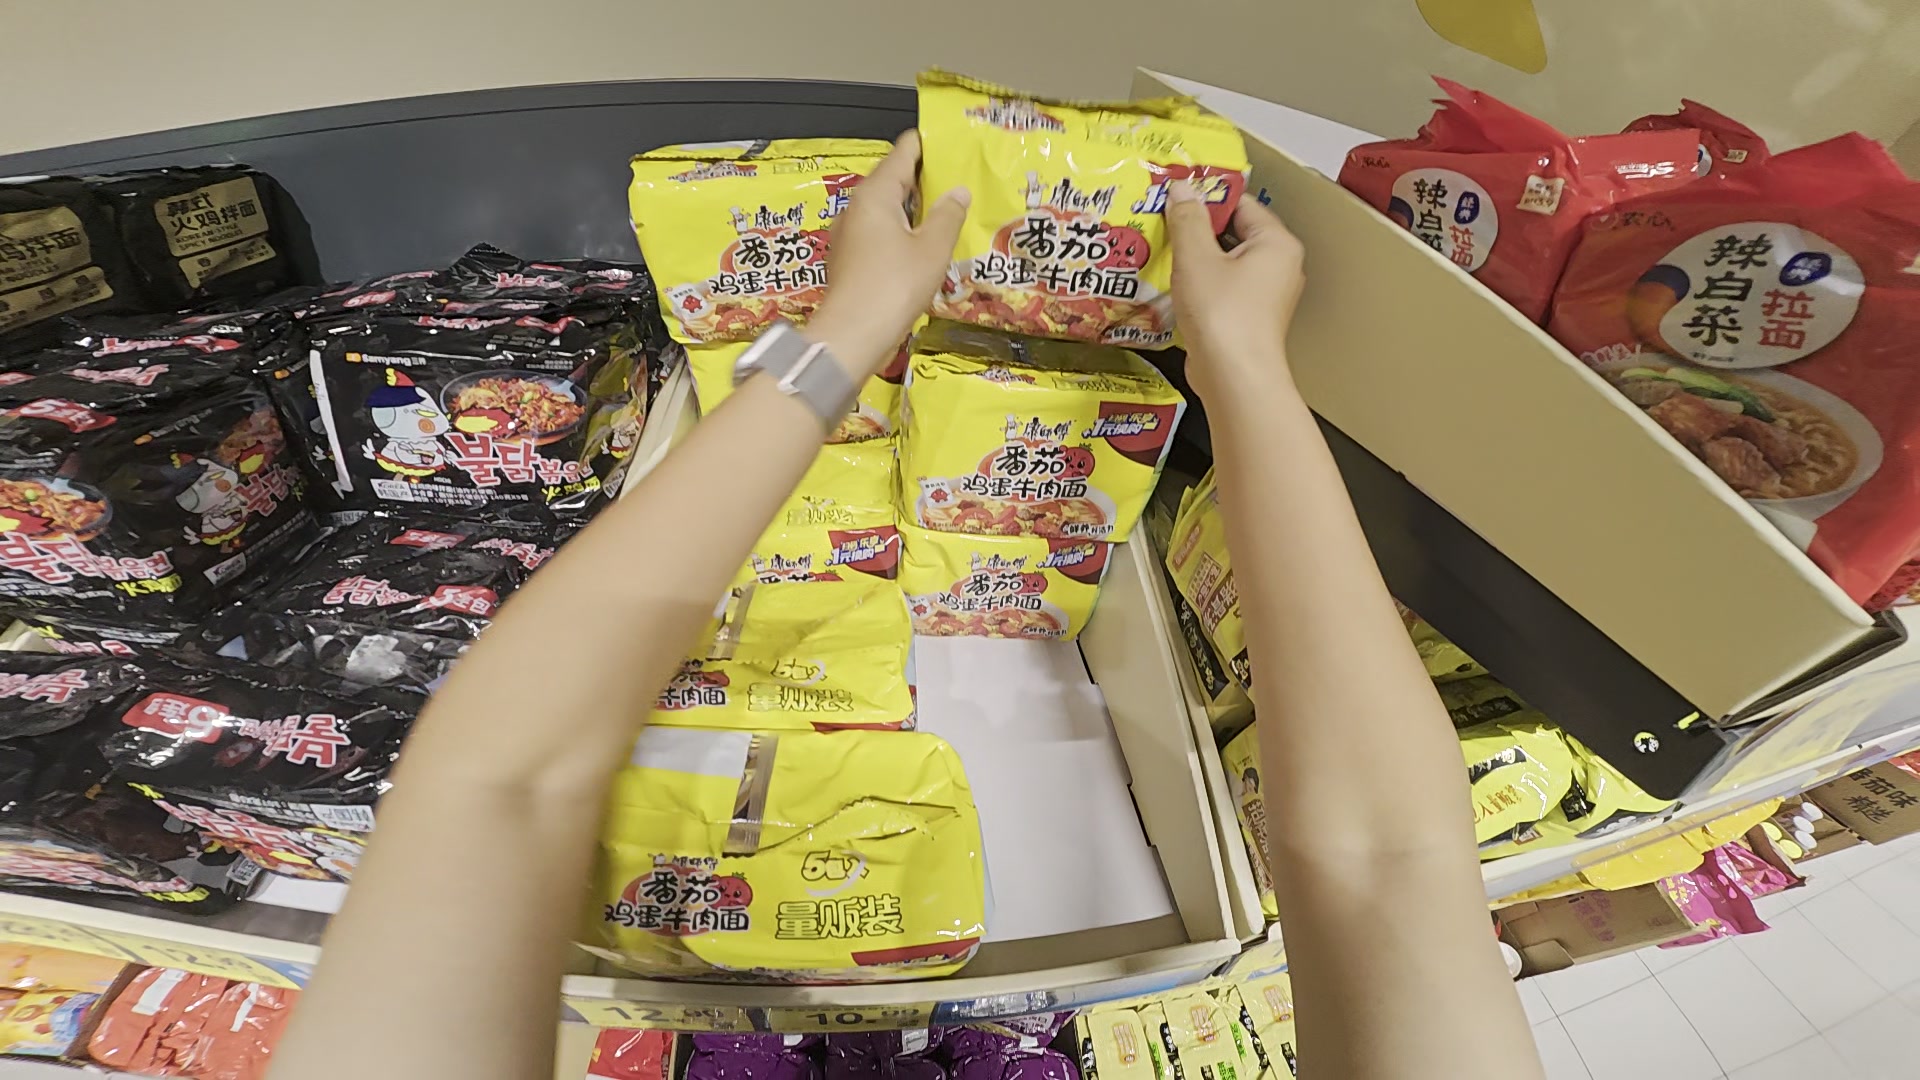
Collected in live stores, on real shelves, with real products. First-person operators move through everyday tasks while the data preserves natural light, occlusion, reflections and customer traffic.

Enter
Live context
Record
Continuous task
Verify
Task outcome
Trace
Dataset version
The environment stays complexShelves, lighting, traffic, occlusion and real routes remain intact.
The task stays continuousContext, outcome, failure and recovery stay connected.
03 / Per-Site Collection Output

Real Work.Measurable Output.

Cumulative hours reveal the data output of each collection site.

Average cumulative hours per site
≈1,813hours
Highest cumulative hours at one site
2,969.20hours
TOP 8

Leading sites by cumulative collection hours

04 / Retail Task Graph

Retail Task Graph

Real store videos are decomposed into reusable action chains — replenishment, processing, checkout and backroom fulfilment — then grounded in observable events.

Root
Retail Task GraphVIDEO-GROUNDED ASSET
Work / Video workflows
Shelf replenishmentSnacks · Beer · Daily stock
Fresh merchandisingFace · Align · Restore
Bakery prepFrozen dough · Arrange · Load
Deli processingPrep · Portion · Box
Checkout & paymentScan · Collect · Bag
Backroom pickingVerify · Pick · Pack
Generalized Task
Move Large Load / RestockBackroom trolley to shelf
Face / Align / RestoreReturn the shelf to standard
Arrange / LoadBakery preparation
Unload / Box / LabelBakery output and packing
Cut / Weigh / SealFresh preparation chain
Portion / Box / WrapDeli processing and packing
Scan / Collect / BagContinuous human-device interaction
Pick / Verify / PackTerminal-guided fulfilment
Event Leaf
Move rear stock forward and alignFresh shelf facing
Cut fruit → Weigh → PackFresh preparation
Durian → Weigh → Open → SealFresh preparation
Arrange dough → Load rackBakery preparation
Unload → Box → LabelBakery output
Scan → Collect → BagCheckout
Portion deli food → Seal boxDeli processing
Verify terminal list → Pick → PackBackroom fulfilment
● New tasks & events keep growing →
05 / Data Acquisition Pyramid

A Data Pyramid for Embodied Pretraining and Scene Fine-Tuning

Real first- and third-person video preserves field context. Simulation and synthesis expand scale and long-tail coverage. UMI bridges human manipulation, while teleoperation aligns robot actions with task outcomes.

01 / REALFirst- / Third-Person CaptureLive-store video, task context and continuous work.
02 / SIMSimulation & Synthetic DataScene diversity, failure cases and long-tail pretraining.
03 / UMIUMI DataPortable capture of fine manipulation and object interaction.
04 / TELEOPTeleoperation DataRobot actions, states and task outcomes aligned.
DATA PYRAMID
Teleoperation Data
UMI Data
Simulation & Synthetic Data
First- / Third-Person Capture
06 / Object Universe × Physical Properties

20,000+ SKUs.
A Taxonomy of Physical Reality.

20,000+Interacted SKU Coverage
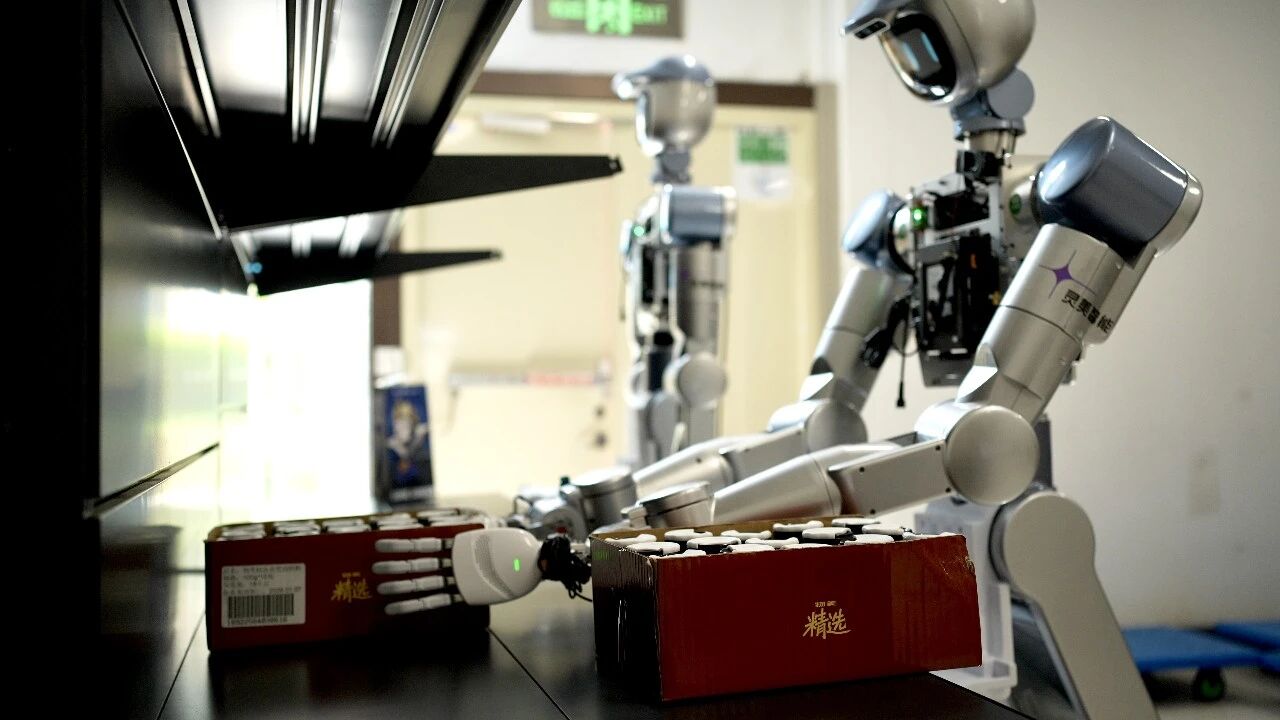
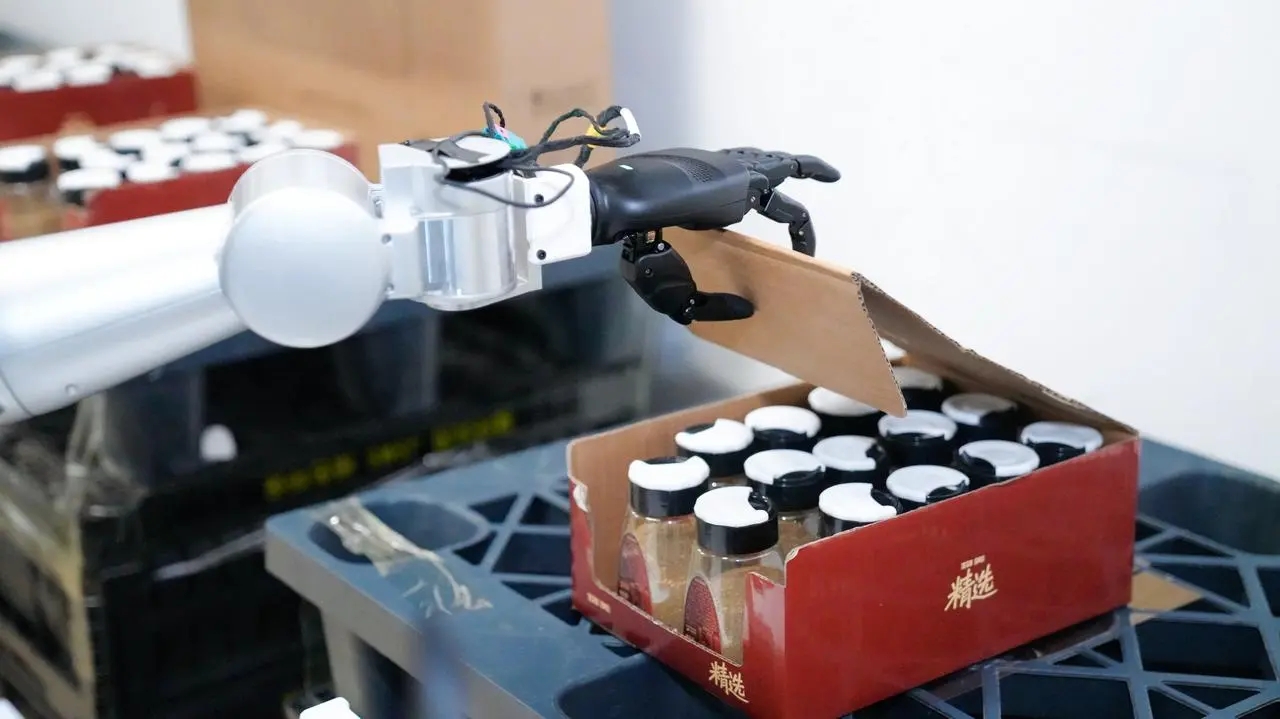
Robot opening a carton of bottled products
ProductPackageCartonContainerTool
Products, packages, containers and toolsPRODUCT · PACKAGE · CONTAINER · TOOL
Flexible packages on a retail shelf
Flexible & deformablePouches · Film · Soft packs · Dough
Rigid bottles and cases
Rigid & case-packedCartons · Bottles · Hard packs · Trays
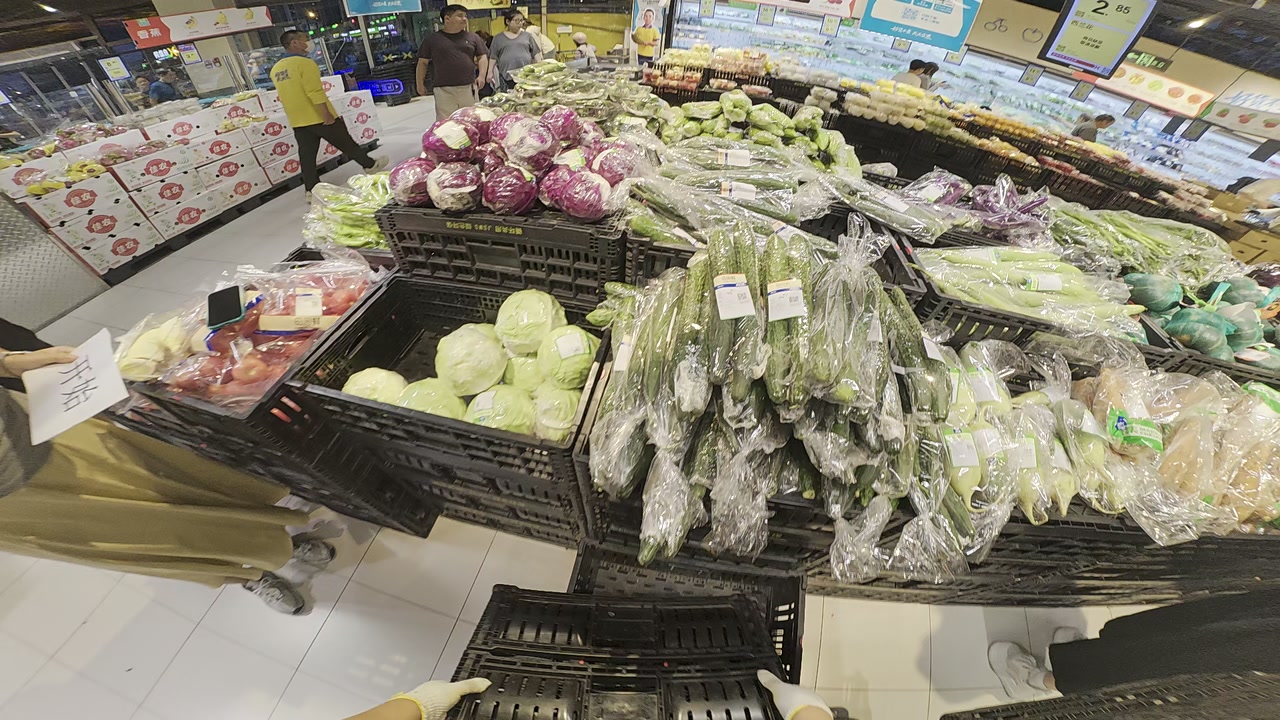
Fresh produce handling in a retail aisle
Fragile & force-sensitiveBaked goods · Eggs · Glass · Produce
Irregular natural products
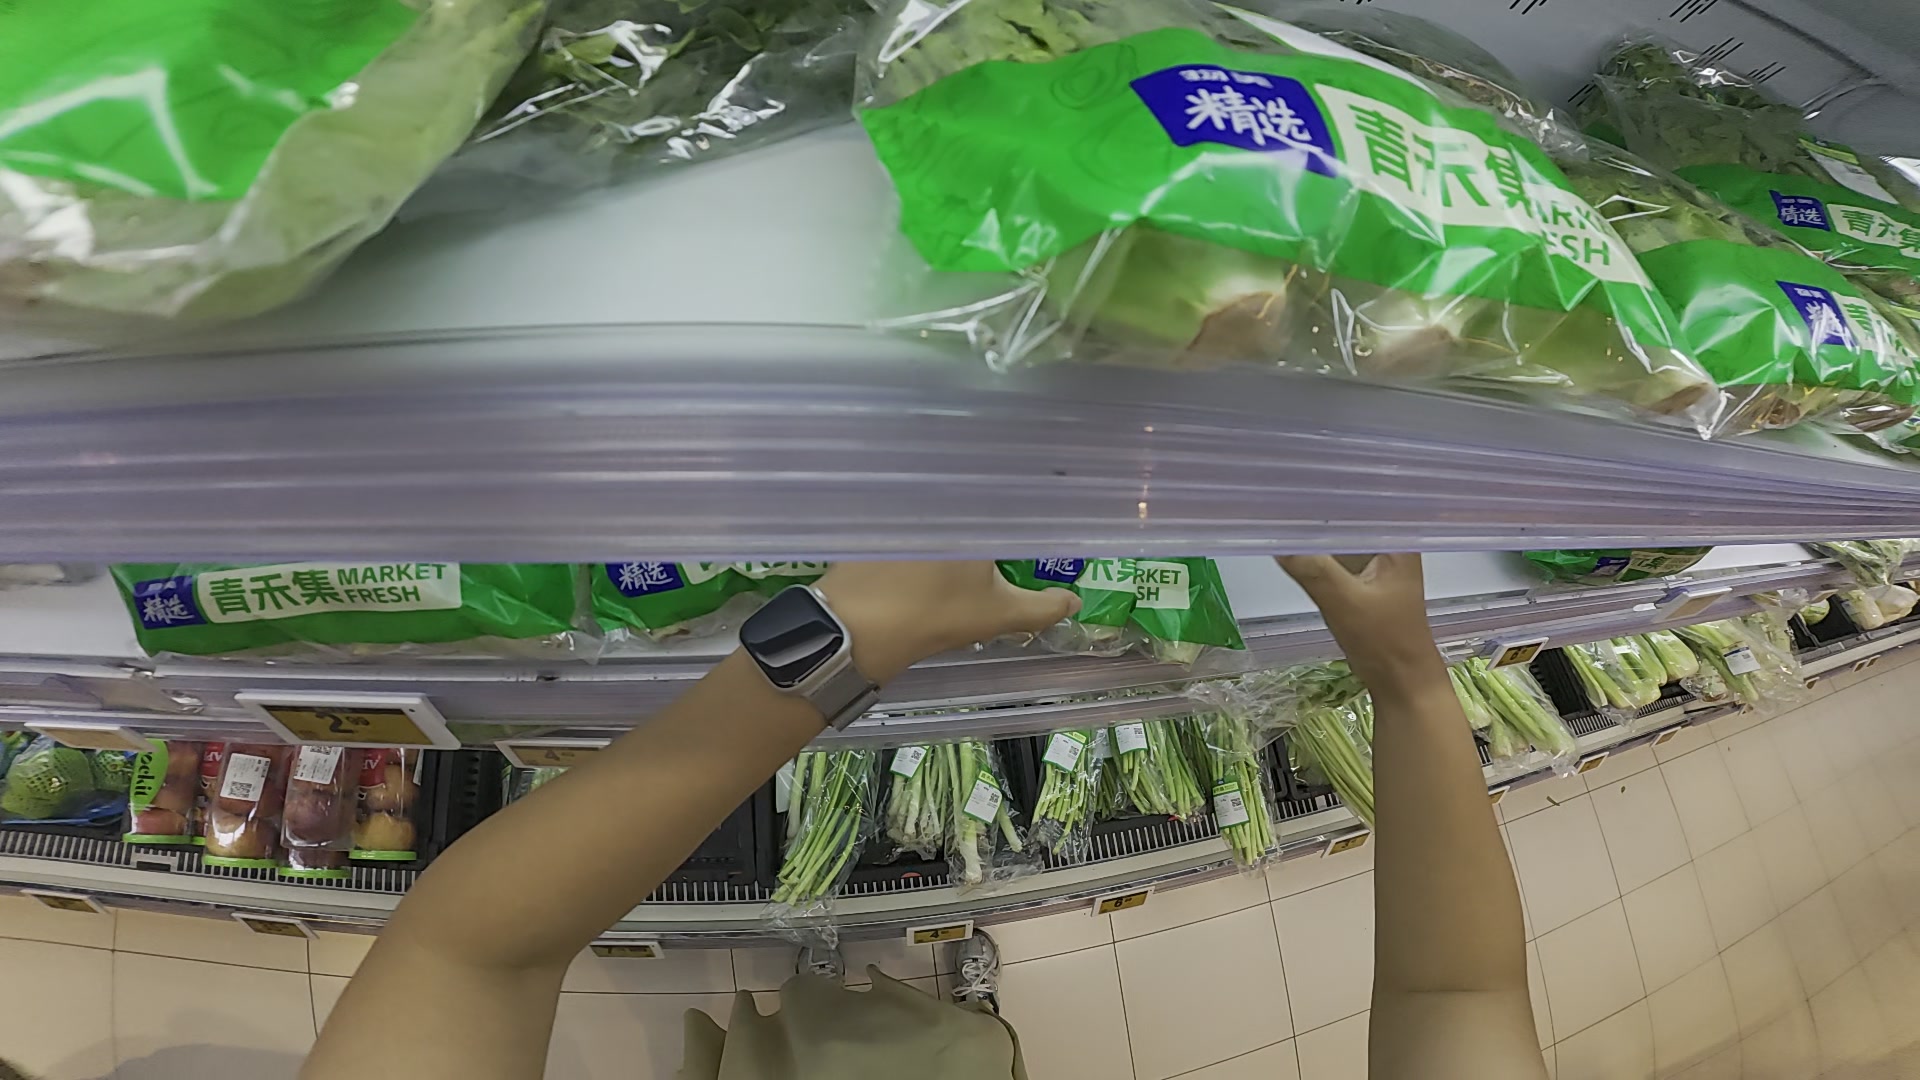
Irregular & naturalLeafy greens · Roots · Produce · Bread
07 / Scene Network × Human–Robot Flywheel

A Store Network Where Human–Robot Collaboration Compounds into Data

Scene coverage creates the validation base. Demonstration, deployment, intervention and event return keep the model moving forward.
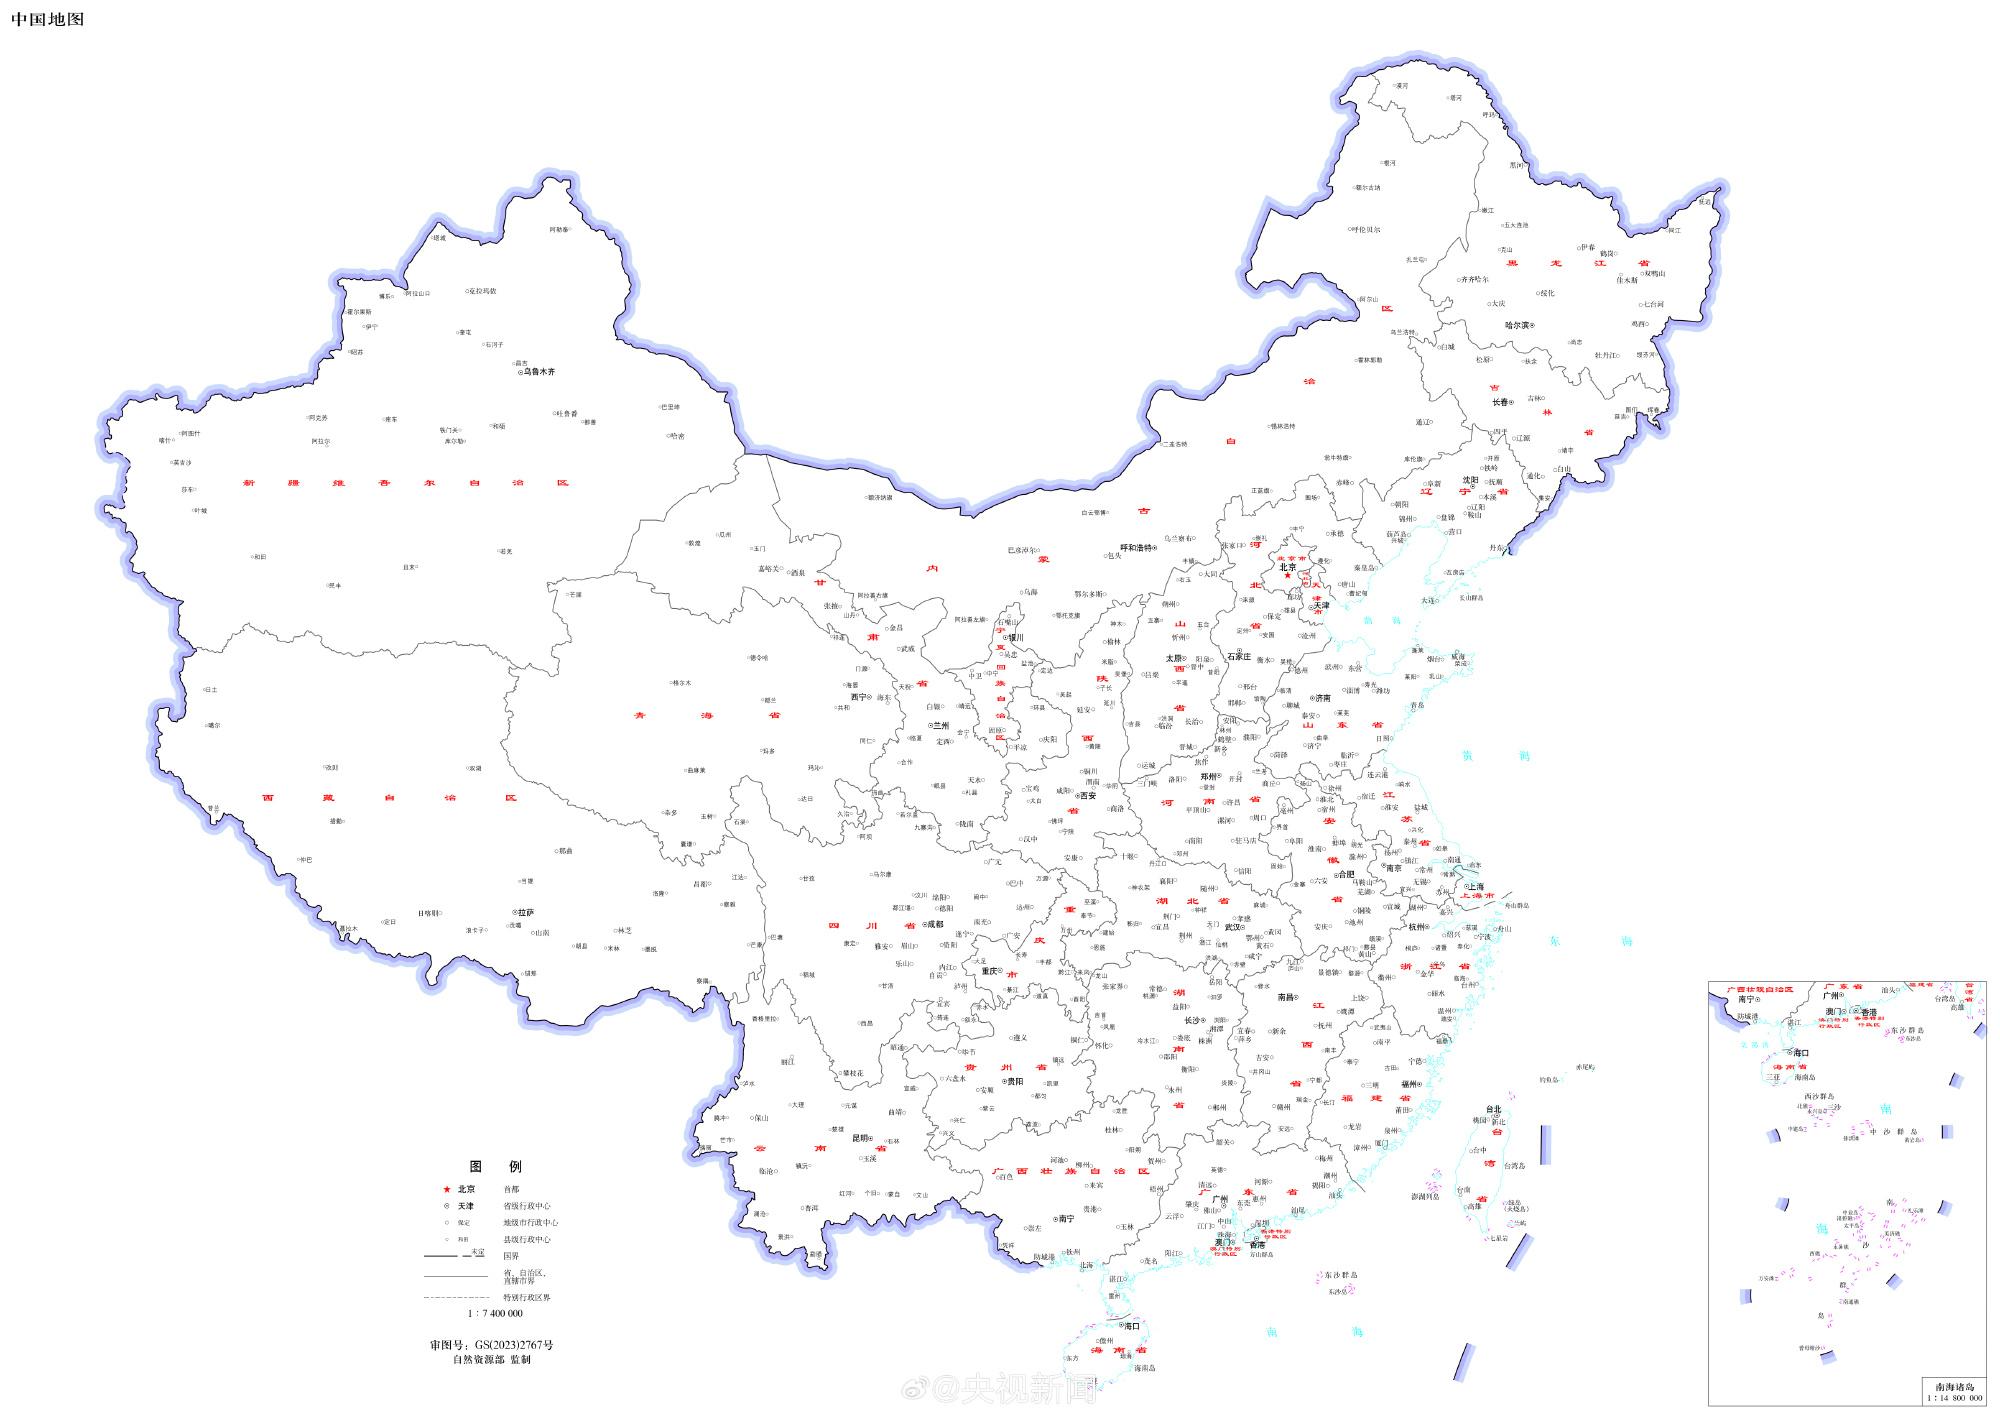
China Retail Scene Network
Complete map of China including Taiwan and the South China Sea inset
Dmall customer scene networkMap approval No. GS(2023)2767 · City lights are illustrative and pending validation
Real scene
Structured data
Model training
Store deployment
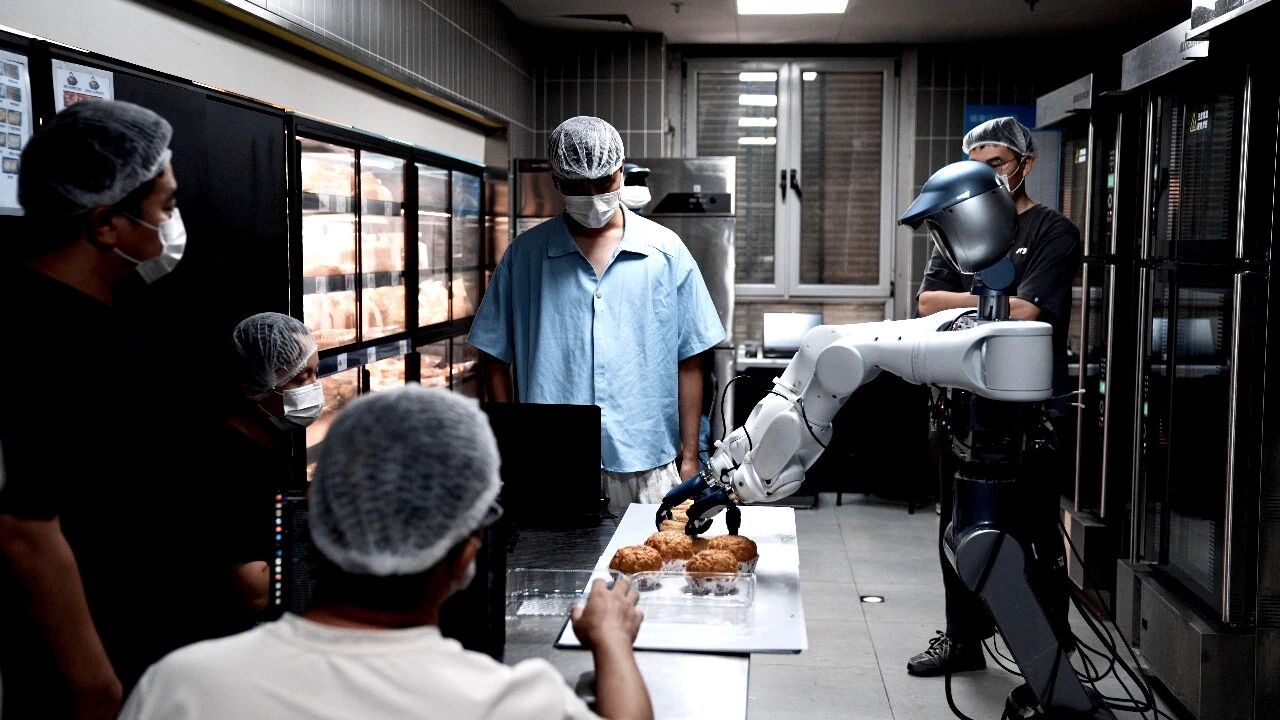
People and a robot collaborating in a retail environmentHUMAN × ROBOT
Human judgment→Robot execution→Event return↺